Iwasa shoot–root–fruit (iwasa_roughgarden_shoot_root)
Question. How should an annual plant allocate between shoot, root, and fruit when production is limited by the scarcer vegetative organ?
Here plant means that three-organ annual.
Formulation
| Symbol | Role | Meaning |
|---|---|---|
| \(S,R,F\) | states | shoot, root, fruit |
| two allocation controls | controls | fractions of photosynthate |
Dynamics (Liebig production).
with \(G\) split among shoot, root, and fruit according to the controls. Fruit is a sink (no return to \(G\)).
Objective. Maximize fruit at the end of a fixed season, \(J=F(T)\).
Constraints. Allocations in the unit simplex; non-negative organs; given \(S(0)\), \(R(0)\), \(F(0)=0\).
What was done
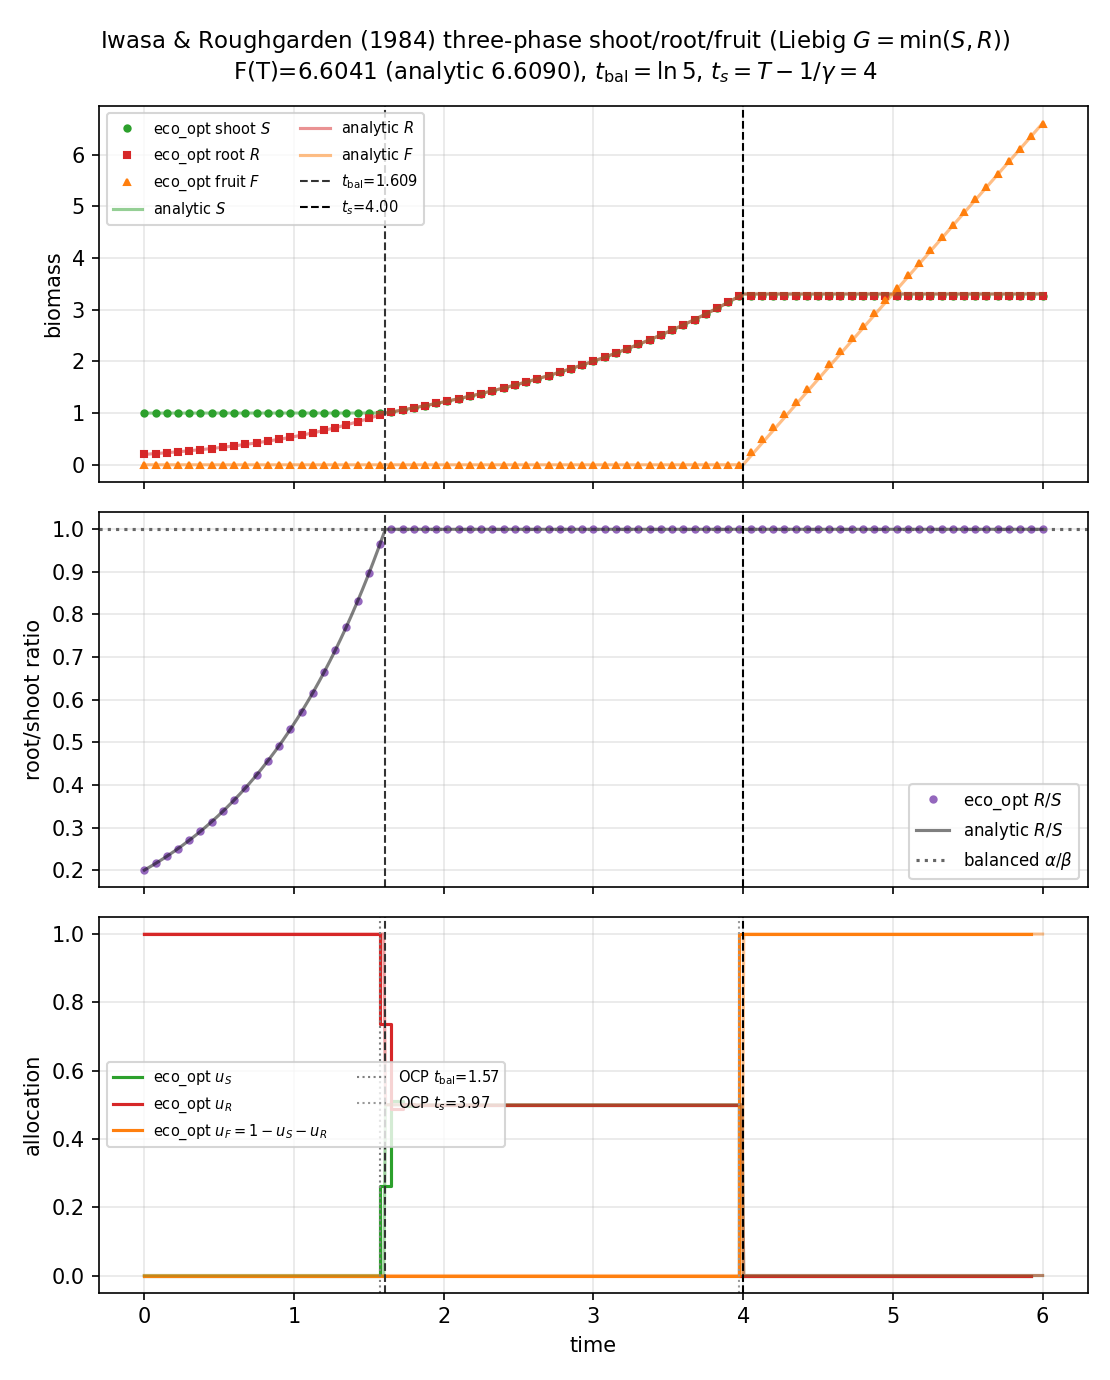
Two controls on one collocation grid (Radau). The Liebig \(\min\) is smoothed slightly for the NLP; the closed-form balanced path is the reference.
What we found
The OCP recovers the three-phase theorem: balance shoot and root, stay on the singular balanced arc, then switch to fruit. Analytic balance time, fruit-switch time, and \(F(T)\) match the numerics.
Interpretation
Splitting the vegetative body into shoot and root is not a cosmetic extra state. The hypothesis “maximize terminal fruit with Liebig production” forces a balanced-growth phase that Cohen’s one-compartment plant never needs.
Public API
Full script: examples/iwasa_roughgarden_shoot_root/shoot_root.py.
import eco_opt
from eco_opt import Namespace

sys = eco_opt.System(states=3, controls=2, model=shoot_root_model)
ocp = eco_opt.Ocp()
ocp.max(eco_opt.t_f(sys.y.F))
ocp.st(system=sys, constraints=[...])
sol = ocp.solve()
Run and tests
cd examples/iwasa_roughgarden_shoot_root
python shoot_root.py
python plot_shoot_root.py
python -m pytest ../../tests/test_iwasa_roughgarden_shoot_root.py -q
References
Iwasa and Roughgarden (1984), Theoretical Population Biology 25:78–105. The three-phase structure is theirs. The production law here is the Liebig special case, not their most general concave class.
Not validated against published figures
Numerics are checked against the Liebig closed form derived in this package, not against figures from Iwasa and Roughgarden (1984).