Bryson–Denham (bryson_denham)
Question. Minimum-energy double integrator whose trajectory must not exceed a path bound on position.
Formulation
Dynamics. \(\dot x=v\), \(\dot v=a\).
Objective.
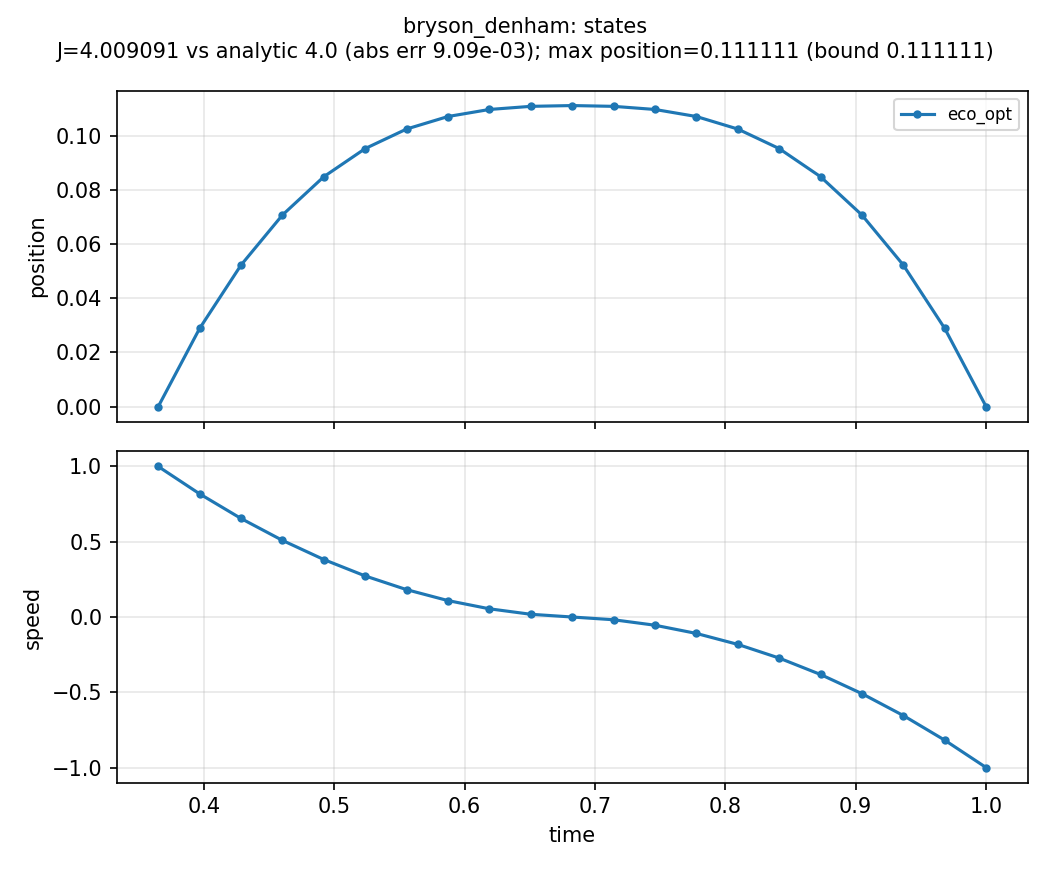
Constraints. \(x(0)=0\), \(v(0)=1\), \(x(1)=0\), \(v(1)=-1\), and the path inequality \(x(t)\le 1/9\).
Horizon. Fixed, \(T=1\).
Closed form: the trajectory kisses \(x=1/9\) on an interior arc and \(J^*=4\).
What was done
Path bound as a constraint on the named position signal. The bound can
be retuned with set_constraints / optimize(warm_start=False)
without rebuilding the mesh. See Build and optimize.
What we found
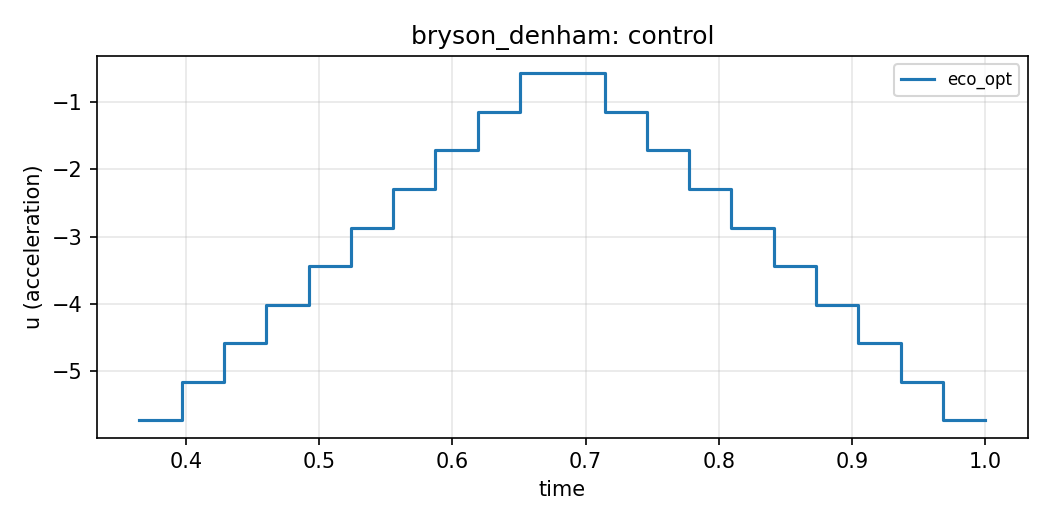
\(J\) matches \(4\) to a few parts in \(10^3\). Peak position sits on \(1/9\). Terminal state matches the specified rest-reversal.
Interpretation
A path constraint is a physiological-style limit: the process may not leave an admissible set at any time, not only at the endpoint. Collocation enforces that at the nodes.
Public API
Full script: examples/bryson_denham/bryson_denham.py.
The path bound is the one-sided form (ub, ">=", expr)
(Constraints and time).
import eco_opt
from eco_opt import Namespace


def trolley_model(t, x, u):
    position, speed, acceleration = x[0], x[1], u[0]
    y = Namespace(position=position, speed=speed, acceleration=acceleration)
    return [speed, acceleration], y


sys = eco_opt.System(states=2, controls=1, model=trolley_model)
ocp = eco_opt.Ocp()
ocp.min([0.5 * sys.y.acceleration ** 2])
ocp.st(
    system=sys,
    constraints=[
        (0, "==", eco_opt.t_0(sys.t)),
        (0, "==", eco_opt.t_0(sys.y.position)),
        (1, "==", eco_opt.t_0(sys.y.speed)),
        (1, "==", eco_opt.t_f(sys.t)),
        (0, "==", eco_opt.t_f(sys.y.position)),
        (-1, "==", eco_opt.t_f(sys.y.speed)),
        (1.0 / 9.0, ">=", sys.y.position),
    ],
)
sol = ocp.solve(control_intervals=20, polynomial_degree=5, tf_guess=1.0)
Run and tests
cd examples/bryson_denham
python bryson_denham.py
python plot_bryson_denham.py
python -m pytest ../../tests/test_bryson_denham.py -q
References
Bryson and Ho, Applied Optimal Control (1975). Also shipped with Yop: Bryson–Denham. The text and code here are ours.
Not validated against published figures
Numerics are checked against the closed-form cost \(J^*=4\), not against figures from Bryson and Ho.